Small drones have become a persistent challenge for modern military forces. They are relatively inexpensive, difficult to detect, and capable of carrying out missions that previously required much larger aircraft. Yet detecting a drone is only part of the problem. Deciding how to stop it, particularly near civilian infrastructure or populated areas, introduces an entirely different set of challenges.
Should every hostile drone be destroyed with a missile? Could electronic interference or physical capture provide a safer alternative? And how can military forces combine these technologies without creating an unnecessarily complicated defensive network?
These questions were central to Falcon Peak 26.2, a counter-unmanned aircraft systems (C-UAS) evaluation conducted at the U.S. Army’s Yuma Proving Ground in Arizona between August 31 and September 25, 2026.
Organized through U.S. Northern Command (USNORTHCOM) and Joint Interagency Task Force 401 (JIATF-401), the event brought together military personnel, government organizations, and 21 participating companies to evaluate emerging counter-drone technologies.
A Different Testing Environment
Falcon Peak 26.2 was the fourth evaluation in the Falcon Peak series, but its location introduced a different operational perspective.
For the first time, the event took place at Yuma Proving Ground, where testing conditions could represent environments associated with the United States’ southern border. The exercise supported USNORTHCOM and Joint Task Force Southern Border, with particular attention given to systems capable of neutralizing drones while minimizing collateral damage.
This distinction matters because battlefield solutions do not necessarily translate into domestic security applications. Destroying a drone over an isolated military range is considerably different from intercepting one near an airport, industrial facility, or residential area. Falling debris, electronic interference, and the possibility of misidentifying an aircraft all become significant concerns.
Even detection presents technical difficulties. Small drones can have limited radar cross-sections, while low-altitude flight introduces ground clutter and line-of-sight restrictions. Electro-optical and infrared sensors can help verify targets visually, although their performance may be affected by visibility, weather, and thermal contrast.
Falcon Peak therefore examined not simply whether a system could defeat a drone, but how it might perform within a broader defensive environment.
Different Technologies, Different Solutions
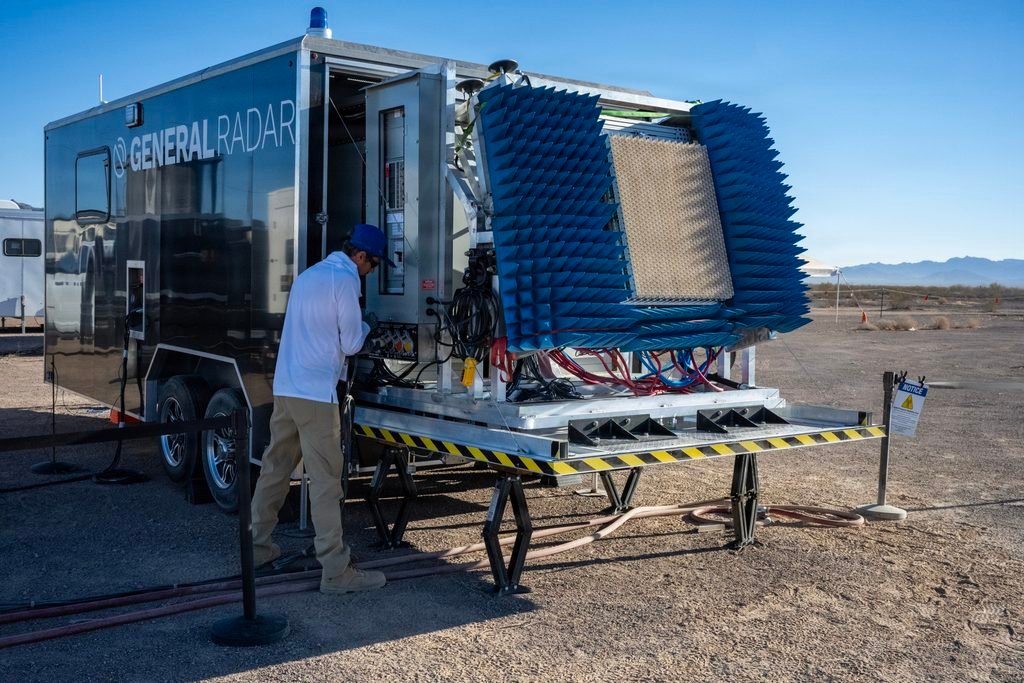
The participating companies included Anduril, BioRes, DataShapes AI, Electro Optic Systems, General Radar, Perseus, Teledyne FLIR, and Zenith Aerotech.
Their technologies represented several approaches to the same problem. Some concentrated on detection and tracking, while others demonstrated kinetic interceptors, remotely operated weapons, and airborne interception systems.
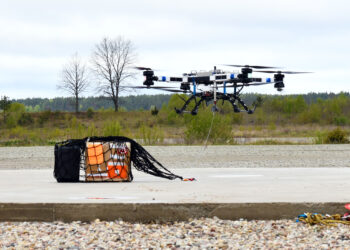
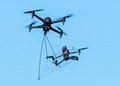
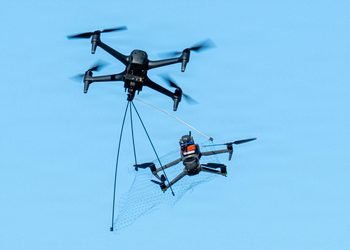
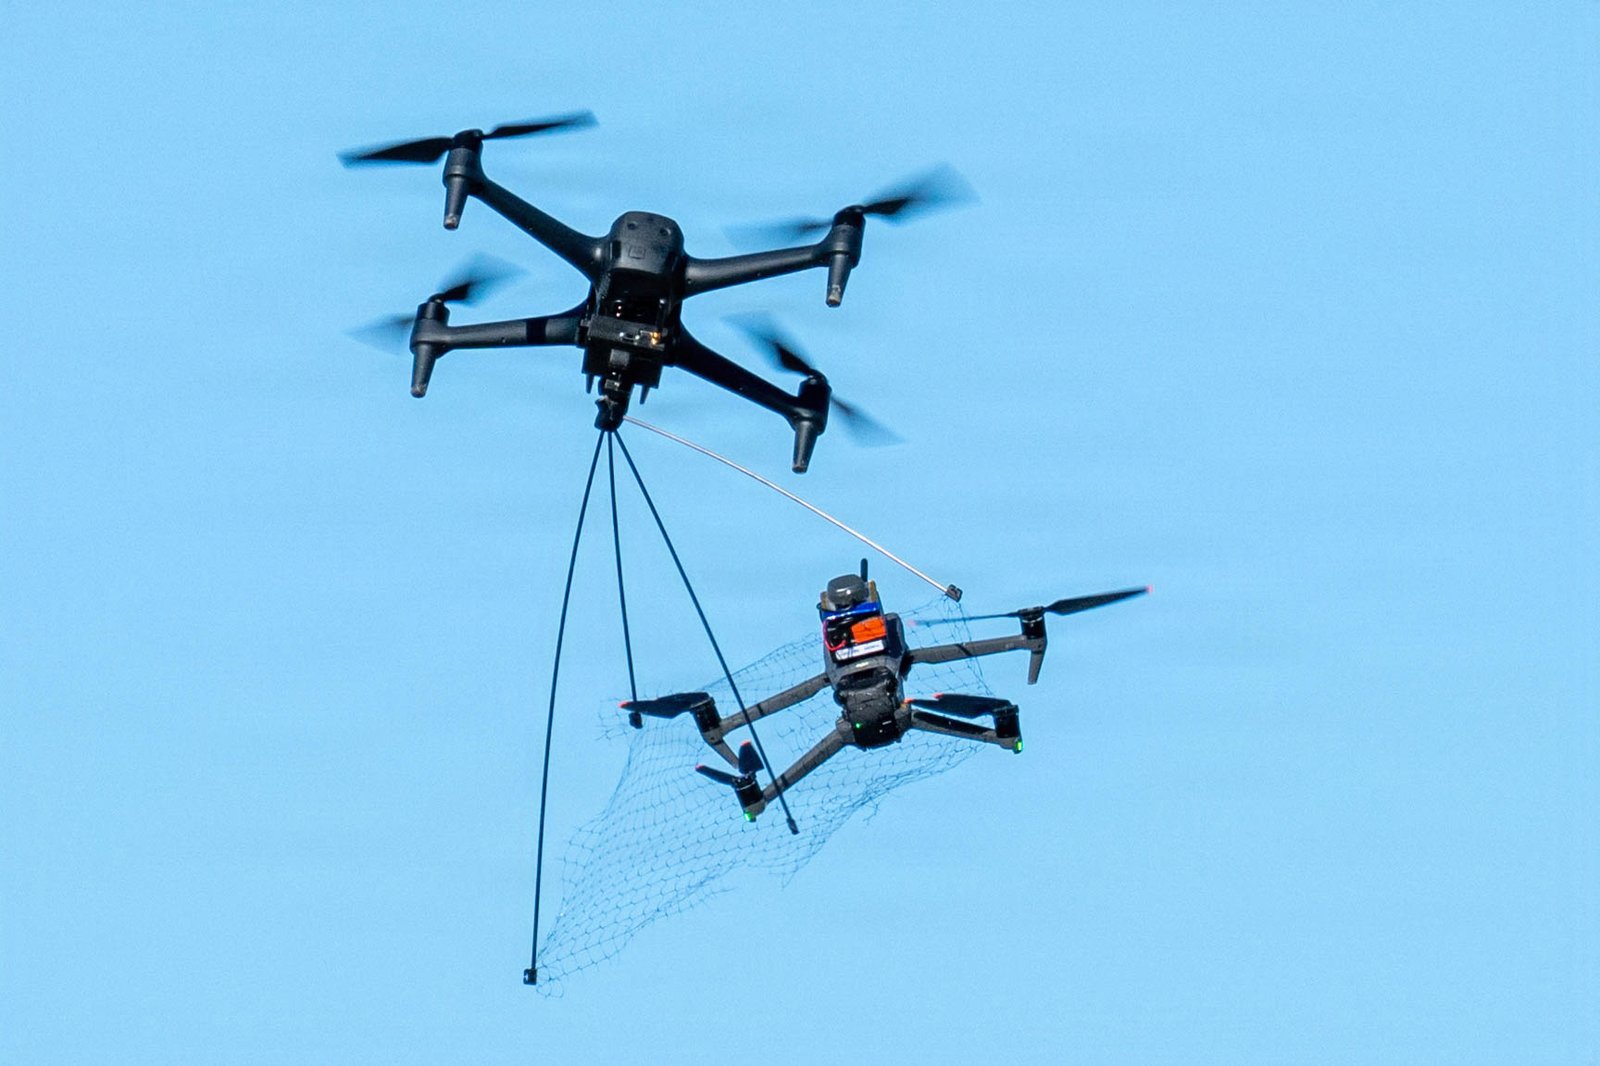
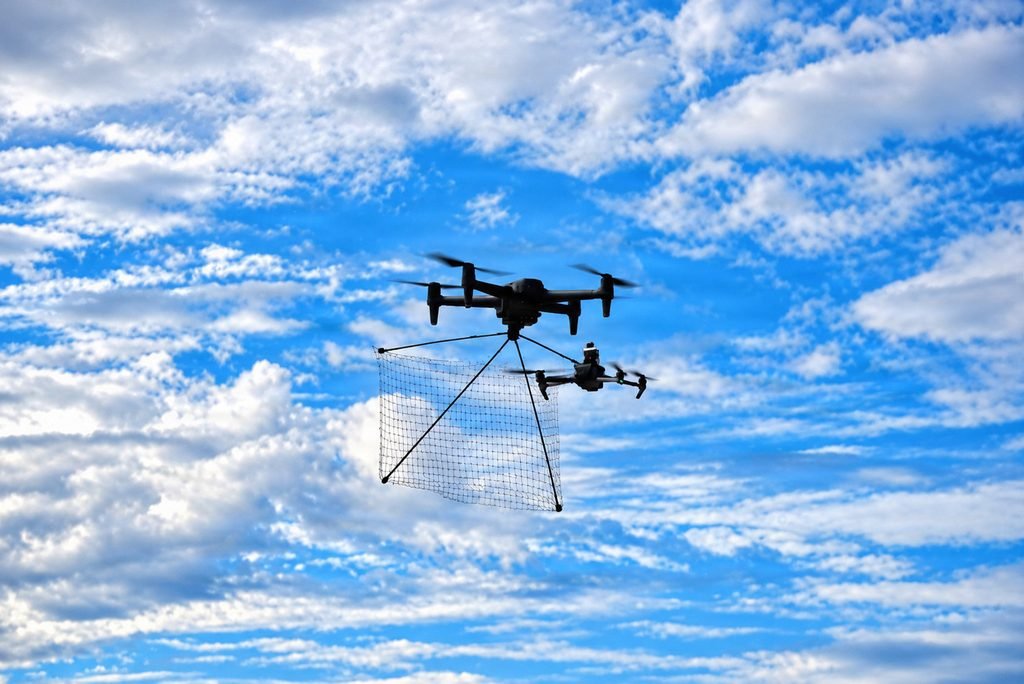
Among the more unusual demonstrations was BioRes’ drone interception technology. During testing in September, the company demonstrated its Aeroo Pro quadcopter equipped with a specialized net-deployment mechanism against small unmanned aircraft, including first-person-view (FPV) drones.
Rather than relying on an explosive warhead, the system releases a net through a radio-controlled mechanism, intending to entangle the target’s propellers and cause mechanical failure. Its effectiveness depends on positioning, relative movement between the aircraft, and deployment timing.
It is an interesting alternative, particularly in environments where explosive interception would create additional risks. However, target speed, maneuverability, weather conditions, and the interceptor’s ability to reach an appropriate position remain important limitations. Even a successfully disabled drone may still fall into a sensitive area.
A successful demonstration also tells us relatively little about long-term reliability. How would the same system perform against multiple approaching drones or under less favorable conditions? Those questions require repeated testing rather than isolated engagements.
Kinetic Weapons Remain Part of the Equation
Despite the growing interest in non-explosive interception, kinetic weapons remained prominent at Falcon Peak.
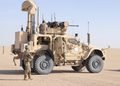
Perseus demonstrated its Portable Kinetic Missile Interceptor System at Yuma’s Cibola Range, with official imagery documenting launch preparations and subsequent interceptor launches. Electro Optic Systems also participated with its R400 remotely operated weapon station, which conducted zeroing shots during the exercise.
These technologies address situations in which physical destruction may be necessary, particularly when other defensive methods are unsuitable or ineffective.
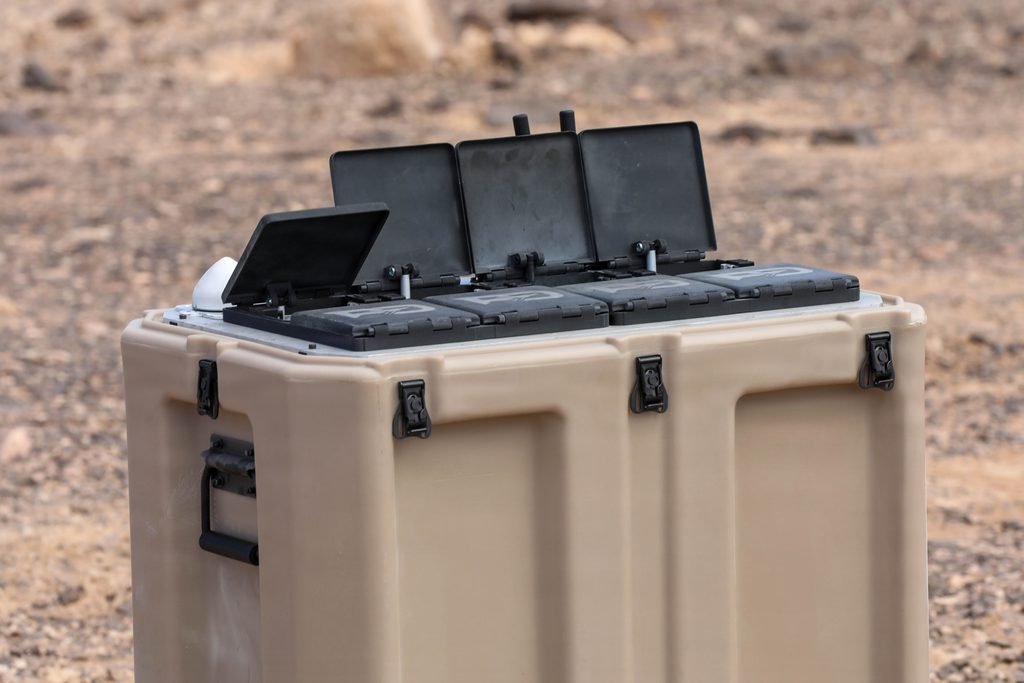
For kinetic systems, successful engagement involves considerably more than delivering a projectile toward a target. Detection accuracy, target tracking, fire-control calculations, and engagement geometry all influence performance. Against small, maneuvering drones, even minor tracking errors can become significant.
However, the economic calculation cannot be ignored. Using an expensive interceptor against a comparatively inexpensive drone can create an unfavorable exchange, especially when threats arrive repeatedly or in large numbers. Ammunition capacity, reloading requirements, and the number of simultaneous engagements add further complications.
Neither system’s presence at Falcon Peak establishes that it offers the most effective or economical solution. Publicly available information does not provide comprehensive comparative performance results, making definitive rankings premature.
Connecting Sensors, Software, and Weapons
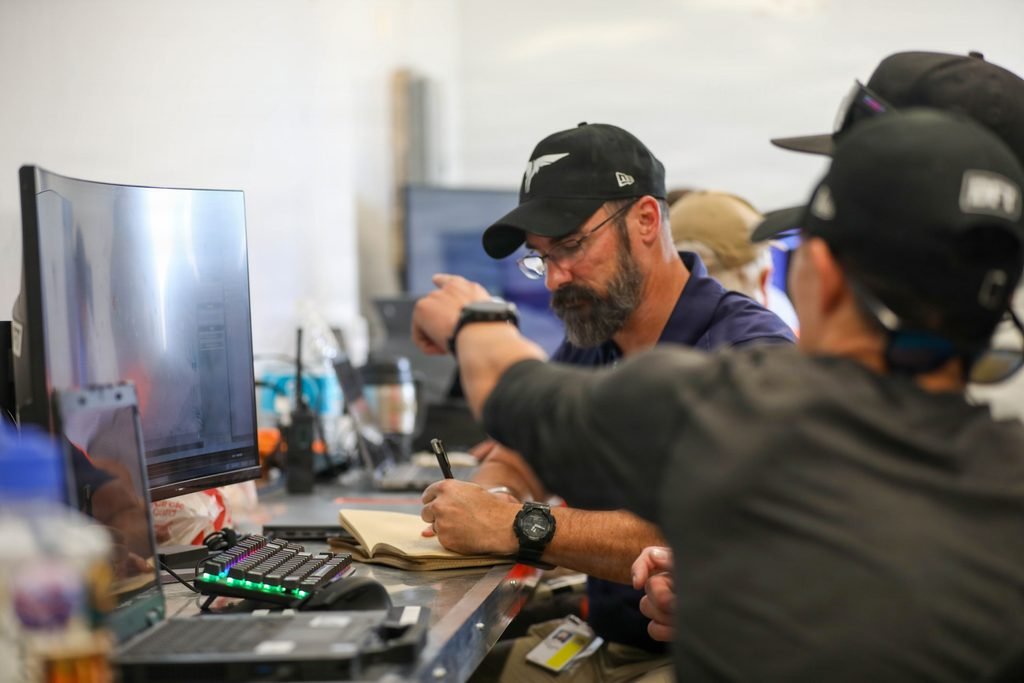
One of Falcon Peak 26.2’s most significant developments involved Anduril’s Lattice platform, which served as the baseline autonomous command-and-control software for evaluating commercial sensor-to-shooter capabilities.
Consider a defensive network containing radar, electro-optical sensors, interceptor drones, and remotely operated weapons. Each component may perform effectively on its own, but their combined usefulness depends on how quickly and accurately information moves between them.
A radar might detect an approaching aircraft, while another sensor helps identify it. The command system must then correlate the incoming data, maintain an accurate target track, and present the information to operators.
This process introduces several technical considerations, including sensor fusion, communication latency, target classification, and interoperability between equipment supplied by different manufacturers. A system that tracks a drone accurately may still be limited if its information cannot be transferred quickly enough to support an engagement.
Automation can improve coordination and reduce operator workload, but it also raises questions about reliability, cybersecurity, and human authorization. Identifying a potential threat is not equivalent to authorizing an engagement, particularly when operations involve civilian airspace.
Falcon Peak’s emphasis on integration reflects the reality that counter-drone defense is increasingly a network problem rather than simply a weapons problem.
Beyond the Demonstration Range
Another development was the establishment of permanent counter-UAS testing lanes at Yuma, covering sensors, electronic defeat, and kinetic engagement.
These facilities are intended to support standardized evaluations, allowing military organizations to assess commercial technologies under more consistent conditions.
For manufacturers, this could provide clearer performance requirements and opportunities to improve their systems. For military customers, repeatable testing offers a stronger basis for procurement decisions than individual demonstrations.
Technical evaluations can examine detection range, tracking continuity, response time, and engagement effectiveness across different environmental conditions. Electronic defeat systems introduce additional considerations, including susceptibility to interference and their effectiveness against drones using different navigation or communication methods.
Still, participation in an exercise does not constitute military endorsement or guarantee a future contract.
Falcon Peak 26.2 demonstrated the variety of technologies being developed to address the drone threat, but it also exposed the complexity of bringing them together. A missile interceptor, a net-capture drone, and an autonomous tracking platform may serve entirely different operational requirements.
The next challenge is determining which combinations can deliver reliable protection without imposing unsustainable costs or creating additional risks. That answer will depend less on impressive individual demonstrations and more on how consistently these systems perform when operating as part of a complete defensive network.
Sources:
- U.S. Army — Mark Schauer (October 1, 2026). U.S. Army Yuma Proving Ground Hosts Major Counter-UAS Test Event.
- Headquarters, Department of the Army — Lt. Col. Adam Scher (September 14, 2026). Department of War Announces Industry Participants in Falcon Peak 26.2.
- Headquarters, Department of the Army — Lt. Col. Adam Scher (September 27, 2026). JIATF-401 and NORAD/NORTHCOM Conclude Falcon Peak 26.2, Establish Enduring Counter-UAS Test Lanes.
- Homeland Counter-small Unmanned Aerial Systems — Michelle Martin (September 7, 2026). Net-capture Demonstration Shown at Falcon Peak 26.2.
- Homeland Counter-small Unmanned Aerial Systems — Michelle Martin (September 7, 2026). A Quadcopter Awaits Takeoff During Falcon Peak 26.2.
- Homeland Counter-small Unmanned Aerial Systems — Staff Sgt. Colten Tessness (September 9, 2026). Falcon Peak 26.2: Testing Continues.
- Homeland Counter-small Unmanned Aerial Systems — Staff Sgt. Colten Tessness (September 14, 2026). Falcon Peak 26.2, EOS R400 Weapon Station Test.